
 MG3505-8
 MG3505-9
 MG3505-36
 MG4315-8
 MG6010-6
 MG6010-8
 MG4305-10
 MG4310-10
 MG4310-36
 MG4310-40
 MG3510-8
 MG3510-64
 MG6010-36
 MG6010-48
 MG8108-6
 MG8108-8
 MG8108-36
 MG8108-48
 MG8115-6
 MG8115-9
 MG8115-36
 T-4024
 T-4929
 T-6034
 T-8938






10 Robot Joint Motor and Actuator Manufacturers: 2026 Sourcing Guide
The useful way to shortlist robot joint motor manufacturers is to identify what each company supplies: a frameless motor kit, a motor-and-gear unit, or a more integrated joint actuator. Those are different purchasing and engineering decisions. This unranked 2026 guide maps ten companies to their documented product families and the questions an OEM should ask before comparing quotations. For an example of packaged joint and servo products, explore the SolisMotor robot joint motor range.
Editorial disclosure. SolisMotor wrote this guide and appears first. The other nine companies follow alphabetically; the numbers are for navigation only. Inclusion is not a performance ranking, partnership claim, or endorsement. Product descriptions were checked against official company pages on October 19, 2026; configurations and availability should be reconfirmed before ordering.
Start with the delivery boundary: motor kit or complete joint?
A frameless stator-and-rotor kit is designed to become part of the customer's own structure. The buyer may still need bearings, a housing, position feedback, a drive, and sometimes a reducer. A motor-and-gear unit moves some of that work to the supplier. An integrated joint actuator may add feedback, power electronics, and control interfaces, but the exact package differs by model. The same word, actuator, does not guarantee the same included parts.
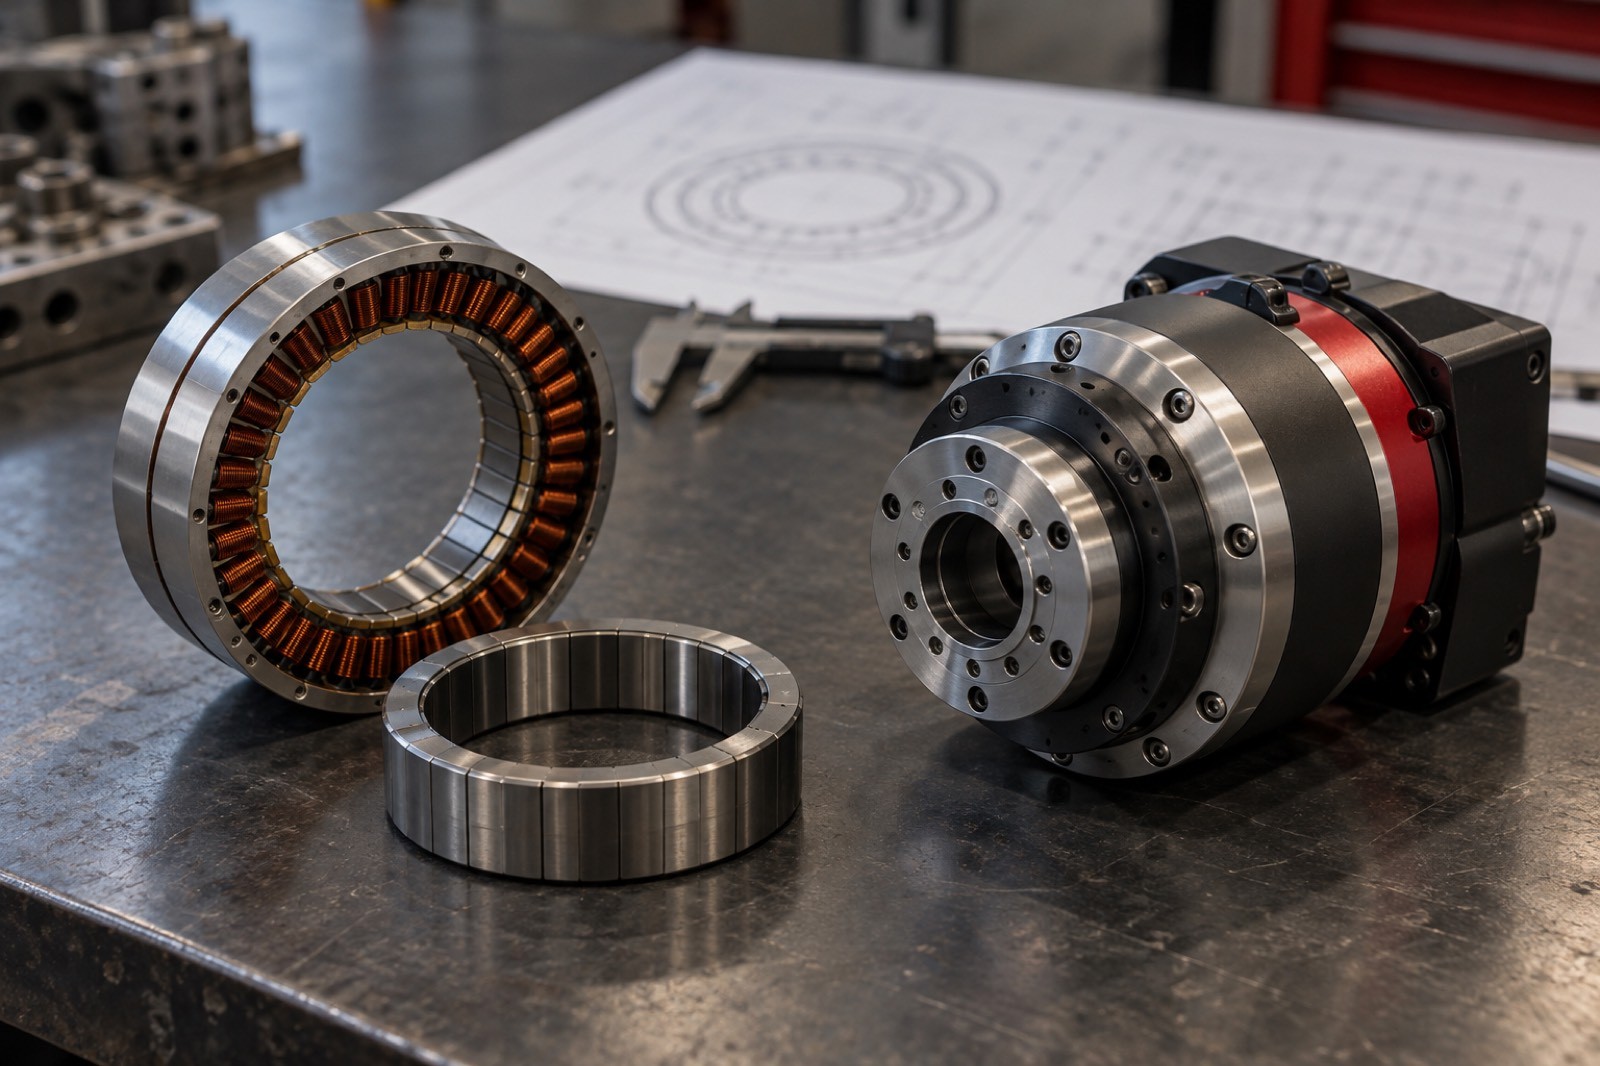
Frameless motor kit
Useful when the OEM controls the bearing, housing, thermal path, transmission, and electronics design.
Motor plus transmission
A packaged motor-and-gear route; feedback and drive electronics must be checked for the selected configuration.
Integrated joint module
More elements can arrive together, but output support, brakes, controls, and software remain model-specific questions.
How these ten companies were selected
Each entry was selected using official documentation for a robot-joint-relevant motor or rotary actuator product family. The list includes component suppliers and integrated-module suppliers because buyers need to distinguish those routes. It excludes companies whose documented offering is only an actuator housing, a stand-alone gearbox, or assembly equipment. The list is a research starting point, not a scored market share or product-performance survey.
The choice of motor size and gear ratio depends on the application rather than one headline number. The MIT Biomimetic Robotics Lab's actuator-design overview (external source) illustrates that design space. It does not certify or endorse any supplier below.
10 robot joint motor and actuator manufacturers to consider
Read the table as a map of product scope. A joint-module delivery layer does not imply that every SKU includes a drive, brake, or output bearing.
On a narrow screen, swipe the table sideways to view every column.
| Company | Documented family | Delivery layer | Confirm for your RFQ |
|---|---|---|---|
| SolisMotor | MG joint actuators; MG-H hollow-shaft servo motors | Packaged joint and servo products | Duty cycle, output loading, interface |
| CubeMars | AK, AKE; RI/RO | Actuator, motor–gear unit, frameless kit | Driver and feedback by SKU |
| Harmonic Drive LLC | FHA-C | Geared servo actuator | Drive, brake and cable path |
| HEBI Robotics | T-, R- and H-Series | Modular joint actuator | Environment and control stack |
| Kollmorgen | TBM2G; KBM | Frameless motor | Bearings, feedback and cooling |
| maxon | EC frameless DT; HEJ; HPJ | Motor component and joint families | Model status and included options |
| ROBOTIS | DYNAMIXEL X, P and Y | Networked actuator families | Exact variant's gearing and brake |
| TQ-RoboDrive | ILM; ILM-E | Frameless motor, custom integration | Sensor and integration scope |
| Unitree Robotics | IM6014 | Geared joint motor | Mechanical and bus interface |
| WITTENSTEIN cyber motor | cyber kit line | Frameless motor kit | Encoder, bearing and drive scope |
1. SolisMotor
Documented offering: SolisMotor's catalog includes packaged robot joint actuators and hollow-shaft servo motors. The MG4310-40 elbow joint actuator is described with a brushless servo motor, planetary reduction, drive electronics, and encoder feedback. The MG-H49-12 hollow-shaft servo motor is a different, compact packaged product with a central bore and integrated feedback. SolisMotor also describes OEM/ODM development and integration support. Before shortlisting: confirm the chosen model's working cycle, joint-side loading, mechanical drawing, cable routing, and control interface.
2. CubeMars
Documented offering: CubeMars lists AK robotic actuators, AKE quasi-direct-drive motor–gear units, and RI/RO frameless torque motors. These belong to different integration layers: an RI/RO motor still needs the customer's joint structure, while an AK configuration can package more functions. A driver board is selectable for some AK products and listed separately for some AKE products; it should not be assumed to be universal. Before shortlisting: specify the exact SKU, included driver and encoders, connector arrangement, and intended operating cycle.
3. Harmonic Drive LLC
Documented offering: The FHA-C family combines a brushless servo motor, precision gearing, and an encoder in a rotary actuator. Its hollow output passage is relevant when cables or tubing must cross the joint axis. This is a geared actuator route rather than a bare frameless motor purchase. Before shortlisting: confirm the selected actuator's compatible drive, brake needs, available bore space, and how moving cables will be protected through the actual range of motion.
4. HEBI Robotics
Documented offering: HEBI lists T-, R-, and H-Series modular actuators. The T-Series is a series-elastic design integrating a brushless motor, gearing, spring, encoders, and control electronics, with Ethernet communication. It represents an architecture aimed at modular robot development rather than an unmounted motor kit. Before shortlisting: choose the appropriate series for the environment and load, then confirm the control API, mechanical mounting, and which features apply to the selected generation.
5. Kollmorgen
Documented offering: Kollmorgen's TBM2G and KBM families are frameless motors intended to be integrated into customer-built axes, including robotic joints. The TBM2G line lists Hall and temperature-sensor options. The motor kit itself should not be mistaken for a completed joint with housing, bearing, gearbox, and drive all supplied. Before shortlisting: match stator/rotor mounting, heat removal, feedback, and the target transmission to the OEM's joint design.
6. maxon
Documented offering: maxon lists EC frameless DT motors alongside High Efficiency Joints (HEJ) and High Precision Joints (HPJ). That range spans a component route and joint-product routes, so the first question is which delivery layer the project needs. The company's HEJ description includes planetary gearing, electronics, and an output bearing for described models; some other capabilities are marked as under development and should not be generalized across the family. Before shortlisting: confirm the current model, included features, and documentation relevant to your interface and duty cycle.
7. ROBOTIS
Documented offering: ROBOTIS's DYNAMIXEL X, P, and Y families are networked actuator products with model-dependent control and feedback features. Y-Series documentation includes frameless brushless motors and multi-turn absolute feedback, while gearing and brake composition vary among Y variants. A family label therefore cannot substitute for a precise part number. Before shortlisting: compare the specific variant's reducer, brake, output mounting, bus, and current availability.
8. TQ-RoboDrive
Documented offering: TQ-RoboDrive's ILM and ILM-E families are frameless motor kits for integration into robot axes. The ILM-E robotics information identifies Hall and temperature sensing as standard features. TQ also discusses customer-specific actuator integration, whose delivered assembly depends on the project. Before shortlisting: separate the standard motor kit from any custom assembly quotation, and check sensors, thermal design, and mechanical fit for the selected motor.
9. Unitree Robotics
Documented offering: Unitree documents the IM6014 as a separately offered geared joint motor, rather than only a component inside a complete robot. Its product information lists motor-side and output-side encoders and an RS-485 interface. Before shortlisting: verify the mechanical envelope, load path, wiring, communication requirements, and current purchase conditions for the exact model. A product page alone does not establish inventory or delivery time.
10. WITTENSTEIN cyber motor
Documented offering: WITTENSTEIN's cyber kit line comprises frameless rotor-and-stator motor products for OEM integration, with hollow-axis and feedback options depending on the configuration. That makes it relevant to a custom robot joint, but the kit is not the entire actuator. Before shortlisting: clarify who supplies the output bearing, transmission, drive, encoder integration, and thermal path in the final joint.
How to compare suppliers without mixing unlike products
- Define the joint task. Give the supplier output torque and speed over time, peak events, holding periods, expected ambient conditions, and the available mass and envelope. Compare continuous and peak torque under stated conditions, not isolated brochure maxima.
- Mark the delivered boundary. For each quote, identify whether the motor, reducer, output bearing, brake, encoder, drive electronics, cables, and software are included, optional, or the OEM's responsibility.
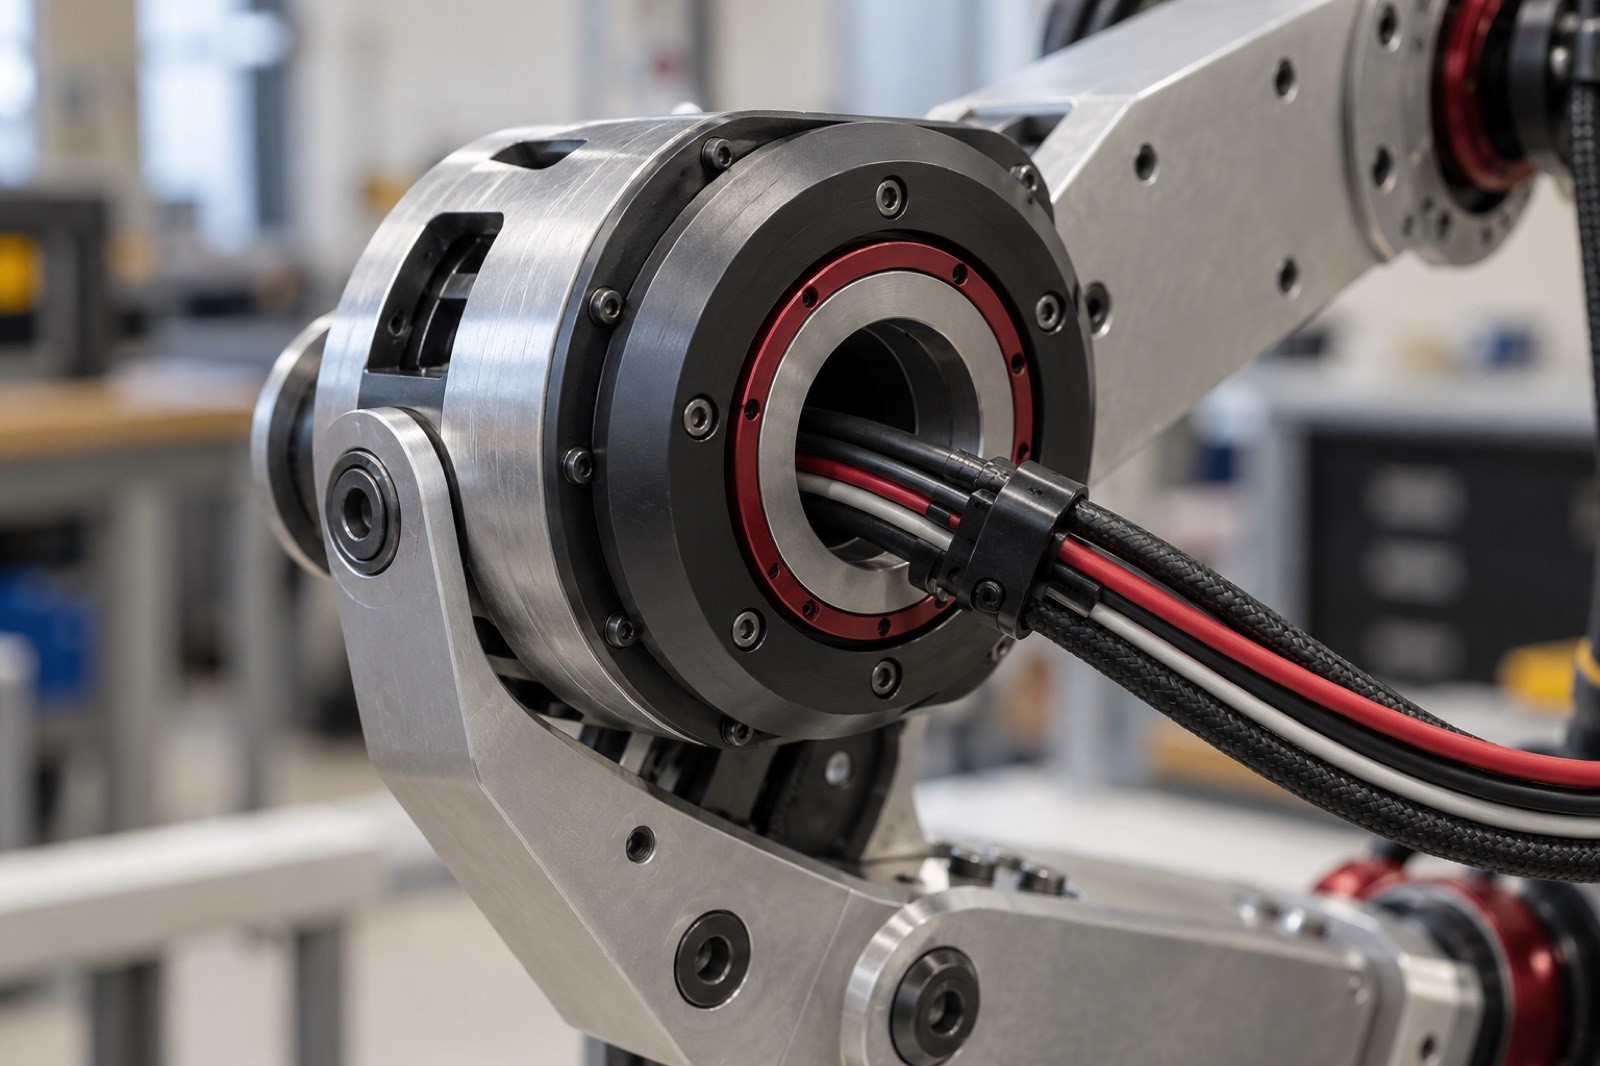
- Check motion and cable routing. Mounting, joint-side radial and axial loads, service access, and the bend path through any hollow bore matter. A hollow bore does not by itself permit unlimited rotation; continuous rotation needs a suitable electrical/fluid transfer strategy.
- Check control evidence. Ask for documented communication modes, feedback location, thermal limits, and tests at your duty point. Encoder resolution alone is not overall joint accuracy. MIT's robotics course notes on transmissions and joint control (external source) explain why gearing affects the relationship between motor current and joint behavior.
- Request comparable documents. Send the same requirement sheet to each candidate and ask for drawings, electrical interfaces, a torque–speed curve with test conditions, thermal assumptions, sample configuration, and support scope. A question left unanswered is a follow-up item, not proof of poor performance.
For the geometry and limitations of this route, see SolisMotor's hollow-shaft servo motor selection guide. For a broader project checklist, see the robot joint motor selection guide.
Common buyer questions
Is a frameless motor a complete robot joint?
No. A frameless motor is normally a rotor-and-stator component that must be integrated into a mechanical and electrical system. Confirm the housing, bearings, feedback, transmission, and drive required by your architecture.
Can peak torque rank these ten companies?
No. Peak torque depends on duration, temperature, voltage, current limit, measurement location, and cooling. It cannot fairly rank dissimilar motor kits and complete actuators without matched conditions.
Does a hollow shaft allow endless joint rotation?
No. A bore provides a path for cables or tubing. The permissible rotation still depends on their routing and on any slip ring, rotary union, or other transfer mechanism required by the application.
What should an OEM send with an RFQ?
Provide the torque–speed duty cycle, space and mass limits, joint loads, range of motion, feedback and communication needs, target voltage, environmental conditions, expected documentation, and the functions you want the supplier to deliver.
Use the list as a scope map, then test against your requirements
The strongest shortlist is the one that matches your axis-level needs and your team's integration capacity. SolisMotor can discuss its robot joint motor portfolio and custom development scope against a documented application brief. For every supplier in this guide, verify configuration, tests, and commercial terms directly before making a design decision.

