
POWERED BY SOLIS
 MG3505-8
 MG3505-9
 MG3505-36
 MG4315-8
 MG6010-6
 MG6010-8
 MG4305-10
 MG4310-10
 MG4310-36
 MG4310-40
 MG3510-8
 MG3510-64
 MG6010-36
 MG6010-48
 MG8108-6
 MG8108-8
 MG8108-36
 MG8108-48
 MG8115-6
 MG8115-9
 MG8115-36
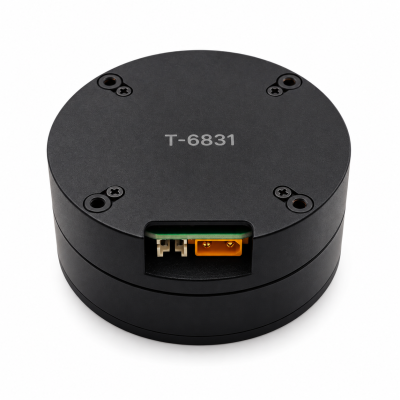
 T-4024
 T-4929
 T-6034
 T-8938






Home / All / Robot Joint Motor / Direct Drive Motor / T-10943 Direct Drive Motor | 36V, 4.0 N·m Rated Torque, 8.5 N·m Peak Torque | For Rotary Fixtures and Turntables
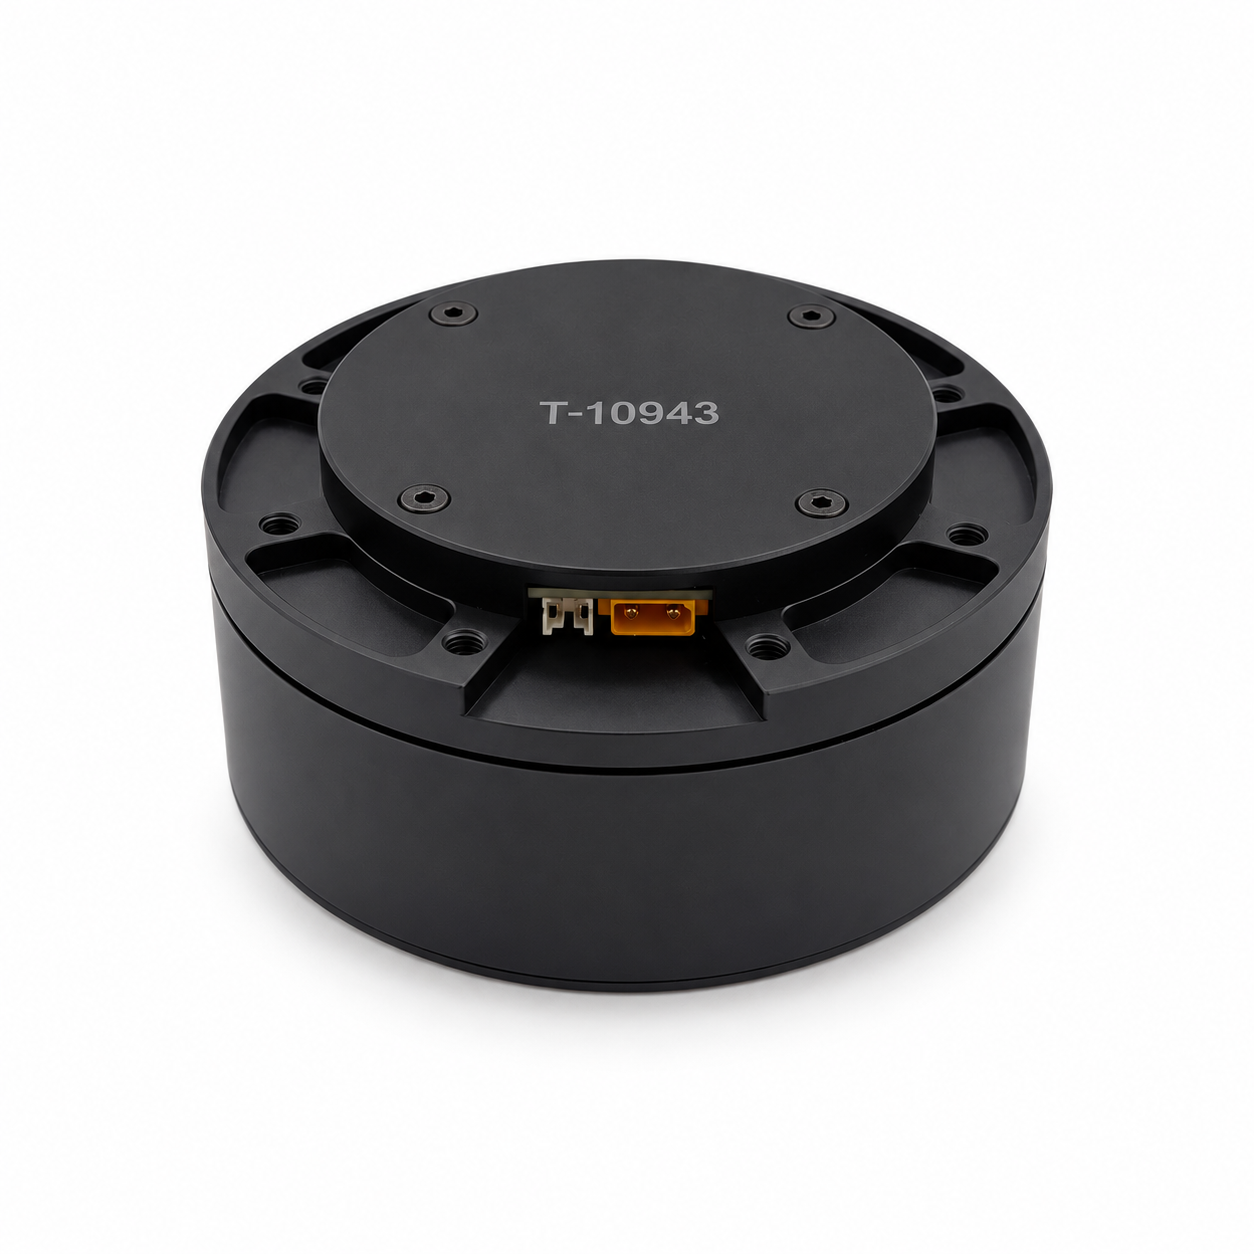
T-10943 Direct Drive Motor | 36V, 4.0 N·m Rated Torque, 8.5 N·m Peak Torque | For Rotary Fixtures and Turntables
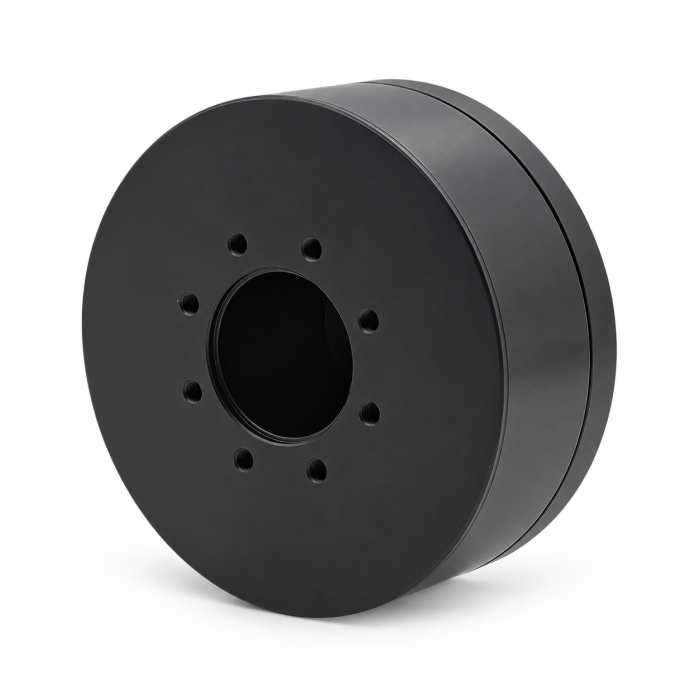
Detail Information
T-10943 Direct Drive Motor
Product Advantages
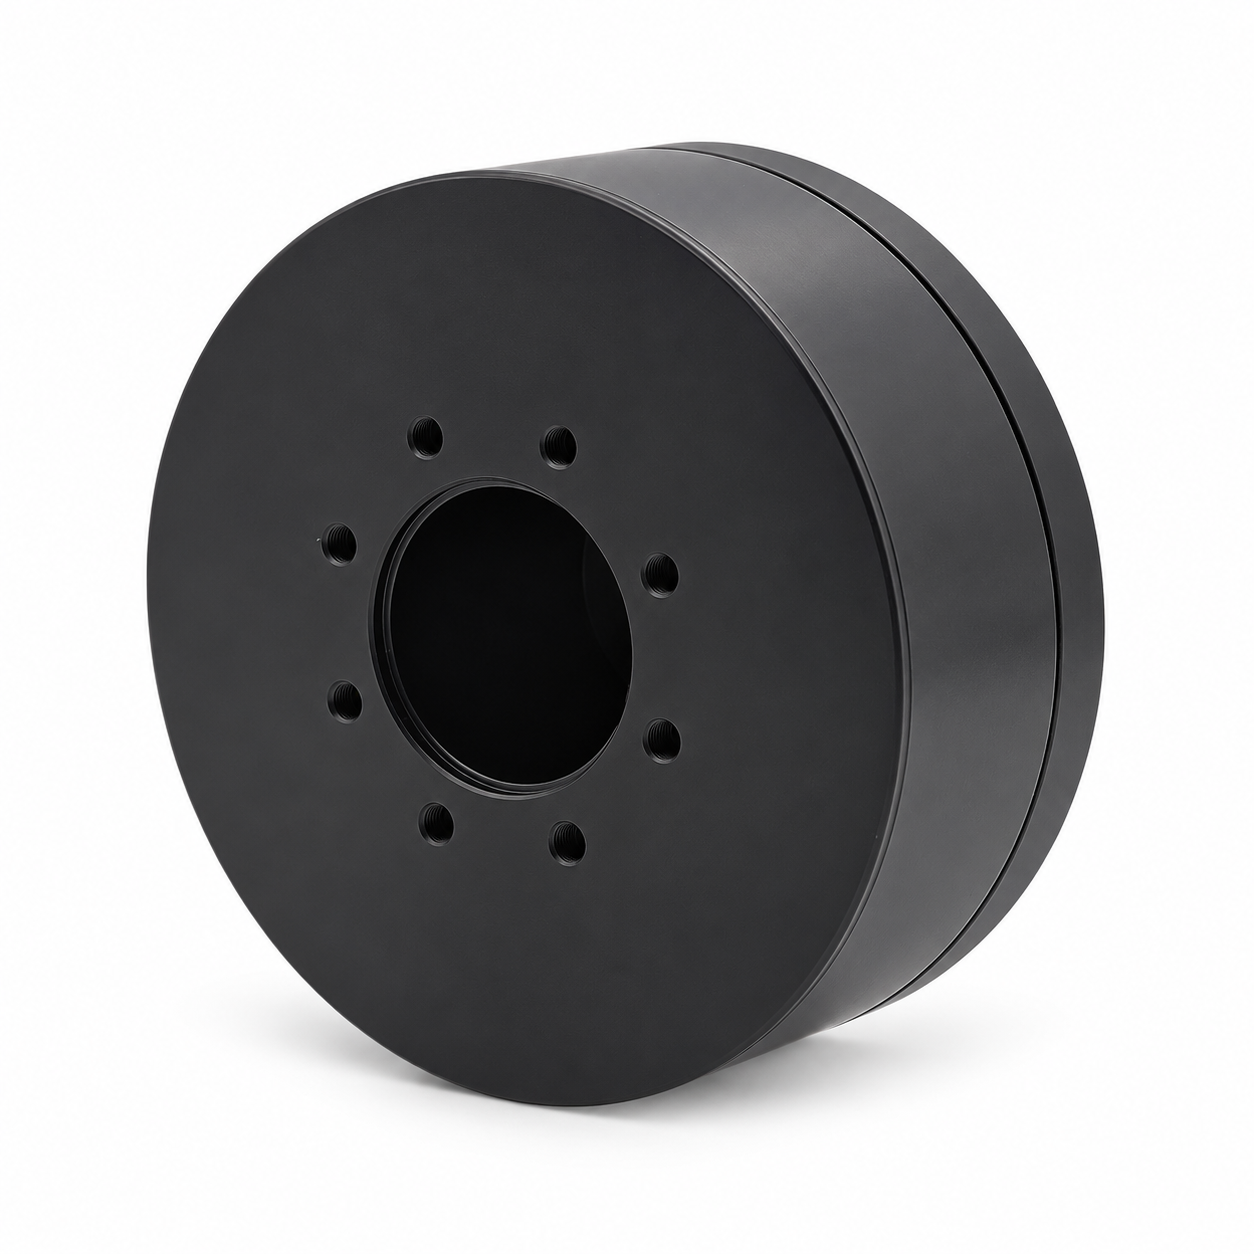
4.0 N·m Rated Torque for Running Resistance
Rated torque is an important selection reference for mechanisms with sustained friction, eccentric load moments or higher running resistance. The T-10943's 4.0 N·m rating can be assessed against lever arms, operating orientation and the duty cycle to determine a suitable drive specification for normal operation.
8.5 N·m Peak Torque for Brief Motion Demands
The 8.5 N·m peak rating provides a reference for assessing acceleration or temporary changes in resistance. A specified peak current of 16 A supports corresponding power-supply and current-limit planning. For turntables with higher platform inertia, peak torque should be considered together with acceleration, its duration and the full operating cycle.
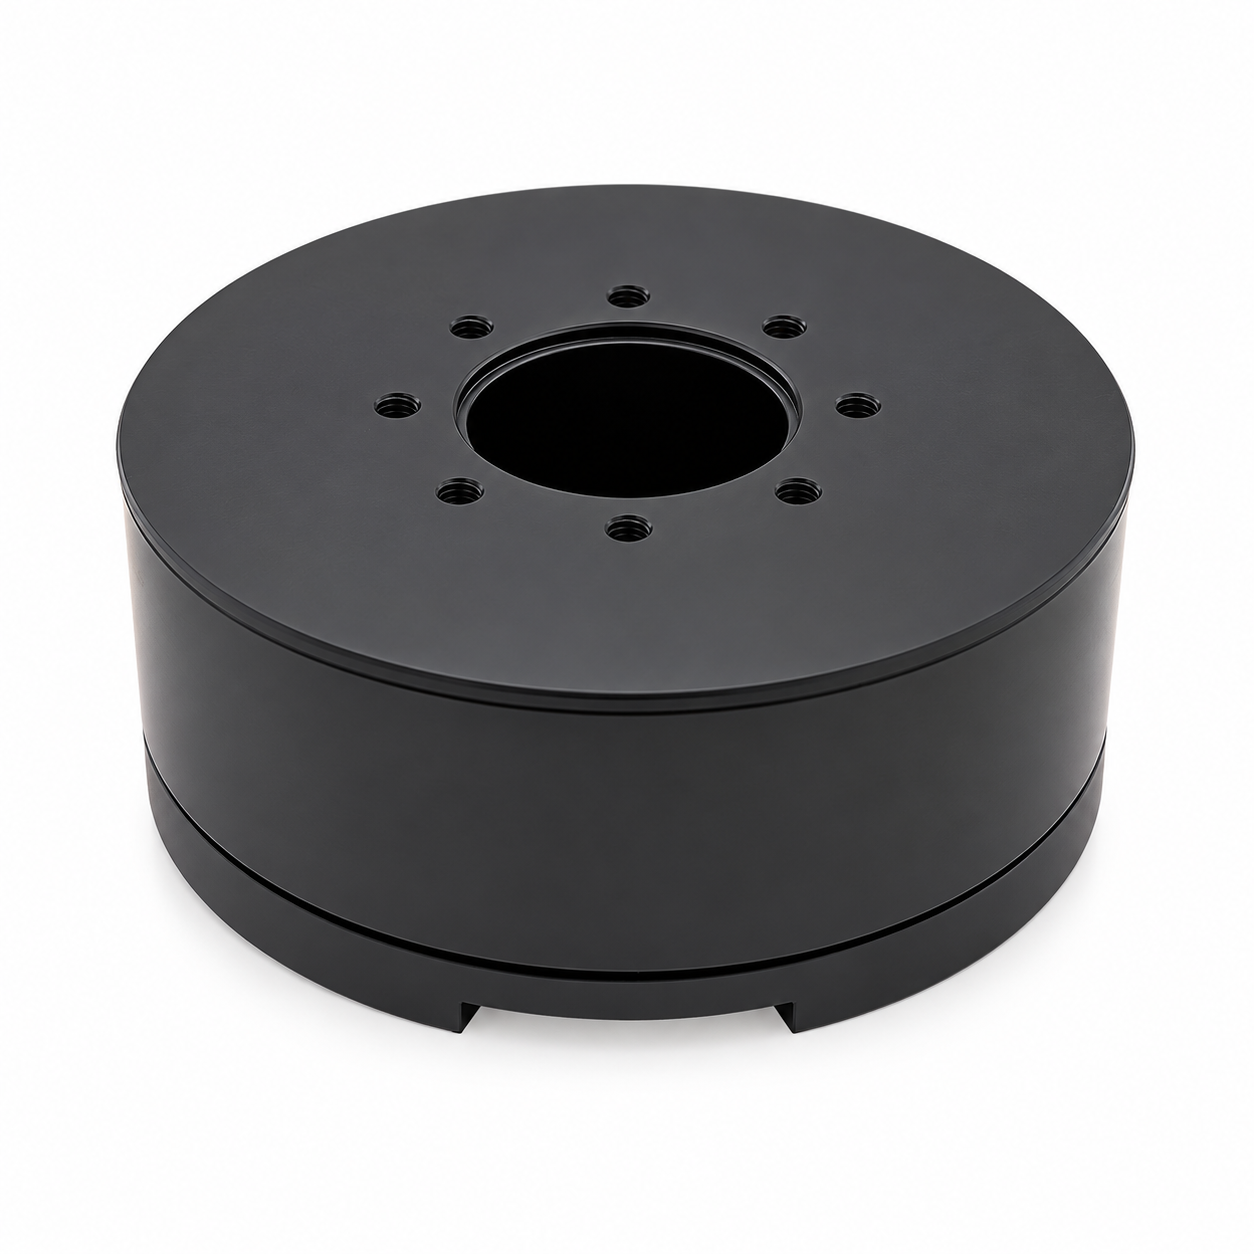
Mechanical Layout for Torque-Priority Applications
The 109 mm outside diameter, 43 mm thickness and 1028 g weight can be incorporated into base and support design from the outset. Fixed fixtures can be laid out around the motor mount and load supports. For moving installations, the motor mass can be included in the upstream mechanism's load calculation to establish a complete space and weight budget.
Matching Fixture Rotation and Limited-Angle Oscillation
Rotary fixtures can be assessed around running resistance, oscillating assemblies around changes in eccentric load moment with orientation, and turntables around inertia and acceleration requirements. The 168 rpm rated speed provides a reference for matching higher torque requirements with the intended operating speed.
Motion Control and System Connectivity
A single-turn absolute encoder provides position feedback. The associated controller supports position, speed and Q-axis current modes for angular positioning, continuous rotation or current-regulation tasks. RS485 and CAN interfaces support connection to the equipment control system. Motor control resolution is 14 bit; actual motion performance depends on the load, mechanical connection and control tuning.
Technical Specifications
ParameterValue
ModelT-10943
Configuration InterfaceRS485
Rated Voltage12-40 VDC
Rated Torque4.0N·m
Peak Torque8.5N·m
Rated Power136.8W
Encoder Resolution14-Bit
CommunicationCAN
Protection RatingIP54
Weight (with driver)~1028 g
Nominal speed168
Noise< 50 dB
Working Temperature-20 ~ +80 °C
Dual Encoder SupportYes (Output Shaft)
Custom Brake SupportYes
Key Applications
Humanoid Robots
Joint actuation for bipedal and full-body humanoid platforms
Collaborative Robots
Safe, precise motion for cobot arms and grippers
Exoskeletons
Power assist and rehabilitation exoskeleton systems
Education & Research
Robotics labs, university projects, and prototyping
Medical Assistants
Surgical robots and rehabilitation equipment
Smart Automation
Automated guided vehicles and smart manufacturing
Related Products

Review
- 加载中···
Please send your message to us
- *Name
- *Title
- *Content
POWERED BY SOLIS
Please send your message to us
- *Name
- *Title
- *Content