
POWERED BY SOLIS
 MG3505-8
 MG3505-9
 MG3505-36
 MG4315-8
 MG6010-6
 MG6010-8
 MG4305-10
 MG4310-10
 MG4310-36
 MG4310-40
 MG3510-8
 MG3510-64
 MG6010-36
 MG6010-48
 MG8108-6
 MG8108-8
 MG8108-36
 MG8108-48
 MG8115-6
 MG8115-9
 MG8115-36
 T-4024
 T-4929
 T-6034
 T-8938






Home / All / Robot Joint Motor / Direct Drive Motor / T-4929 Compact Direct Drive Motor | 24V, 0.2 N·m Rated Torque | 49 × 29 mm | For Small Turntables and Sensor Positioning
T-4929 Compact Direct Drive Motor | 24V, 0.2 N·m Rated Torque | 49 × 29 mm | For Small Turntables and Sensor Positioning
Detail Information
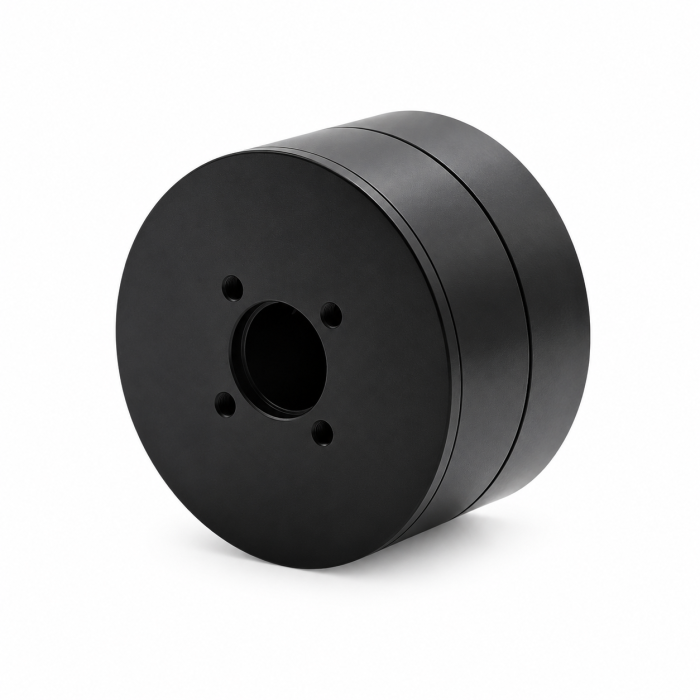
When a motor is mounted on an oscillating component or moving bracket, its own weight adds to the load on the upstream mechanism. At 70 g, the T-4024 helps designers manage the drive's mass budget while leaving more allowance for sensors, brackets and connecting parts, provided its output meets the application requirements. The 49 mm outside diameter and 29 mm thickness provide clear dimensions for designing mounts and housings. For equipment with the drive beneath the rotating platform, the axial dimension helps define the base layout. The 134 g motor weight can also be included in the mass budget of moving or tracking assemblies. A rated speed of 504 rpm provides a reference for normal rotation, while 0.49 N·m peak torque supports assessment of brief acceleration phases. For angular indexing or intermittent rotation, evaluating platform inertia, acceleration and the duty cycle helps establish whether the motor matches the target cycle time. The 24 V rated supply supports integration planning for equipment using a corresponding power platform. Small display turntables can be assessed around the size and torque combination; sensor orientation mechanisms around eccentric loading; and desktop laboratory turntables around speed and mounting conditions. Control modes can then be selected to suit the defined motion task. A single-turn absolute encoder provides position feedback. The associated controller supports position, speed and Q-axis current modes for angular positioning, continuous rotation or current-regulation tasks. RS485 and CAN interfaces support connection to the equipment control system. Motor control resolution is 14 bit; actual motion performance depends on the load, mechanical connection and control tuning. Joint actuation for bipedal and full-body humanoid platforms Safe, precise motion for cobot arms and grippers Power assist and rehabilitation exoskeleton systems Robotics labs, university projects, and prototyping Surgical robots and rehabilitation equipment Automated guided vehicles and smart manufacturing
T-4929 Direct Drive Motor
Small turntables, sensor orientation mechanisms and desktop motion devices may need more torque as loads or acceleration requirements increase, while retaining a compact layout. The T-4929 combines a Ø49 × 29 mm body and approximately 134 g weight with 0.2 N·m rated torque and 0.49 N·m peak torque. It provides an option for rotary mechanisms that need increased output within a small installation envelope. Direct coupling to the rotating load removes the need for an intermediate reduction stage, making the motor’s size and output combination central to a compact turntable design.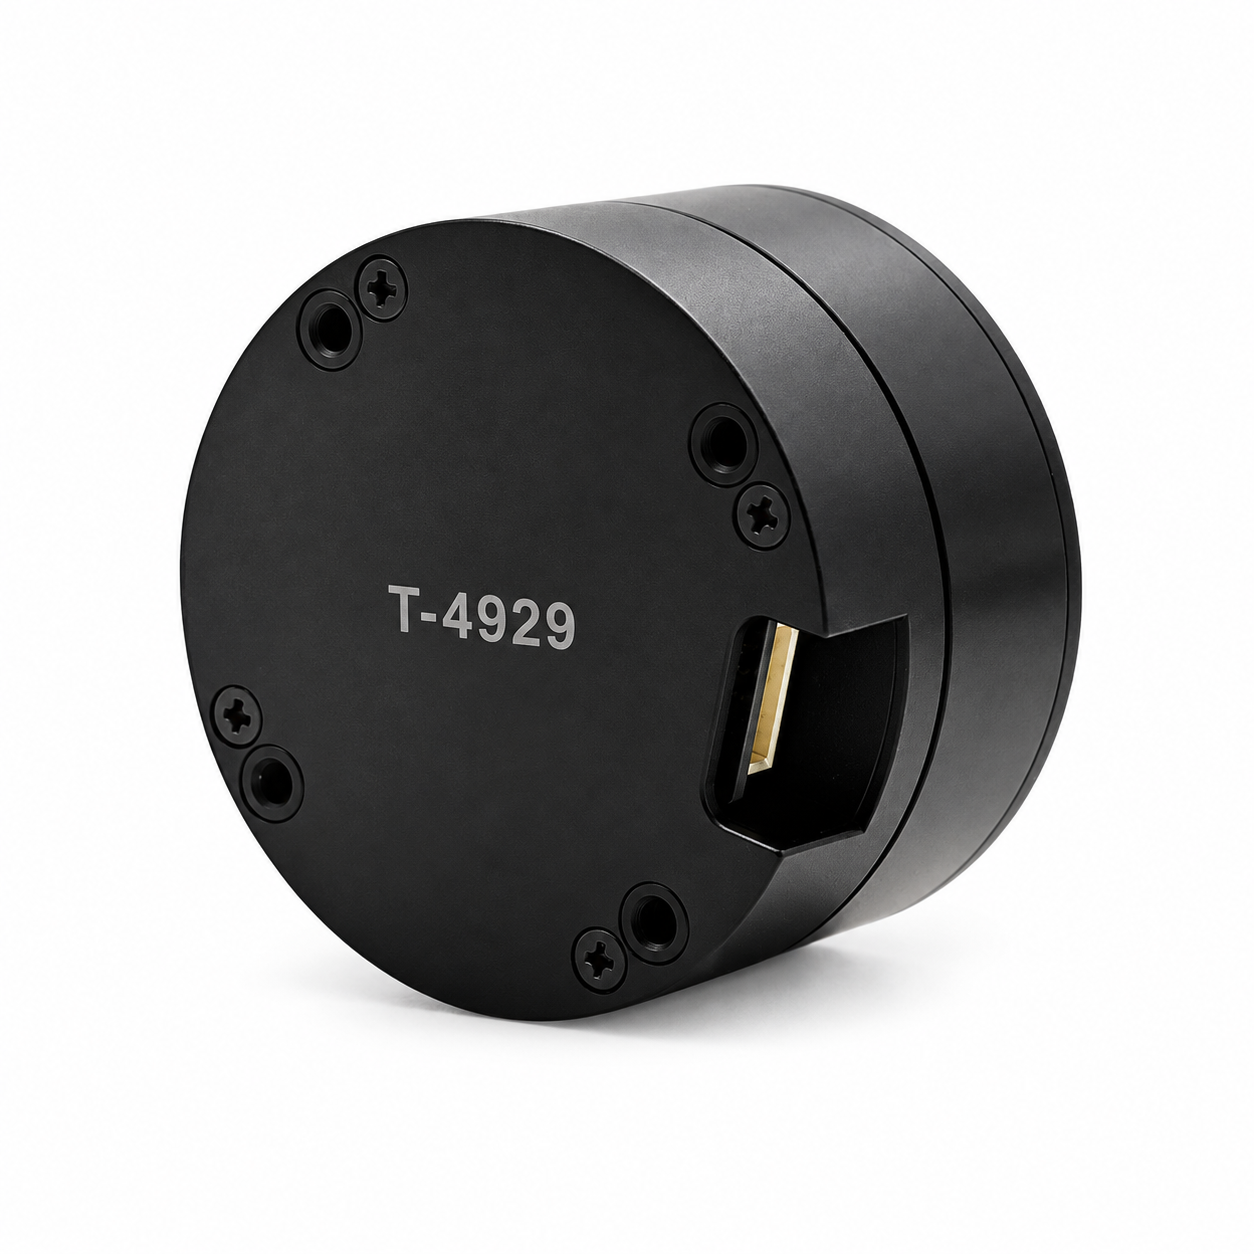
Product Advantages
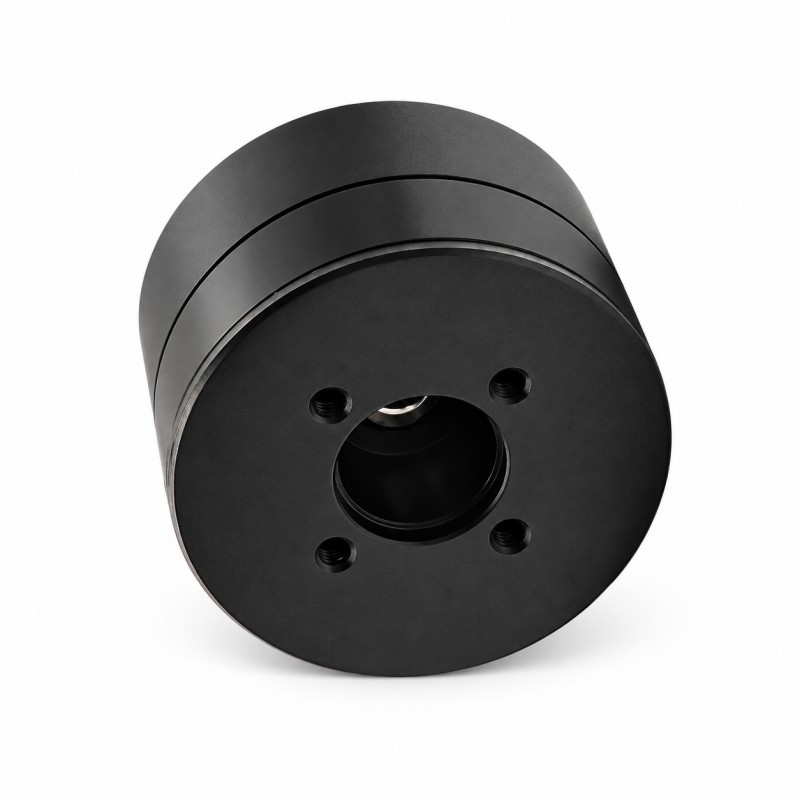
0.2 N·m Rated Torque for Higher Running Resistance
24 mm Body Thickness for Compact Layouts
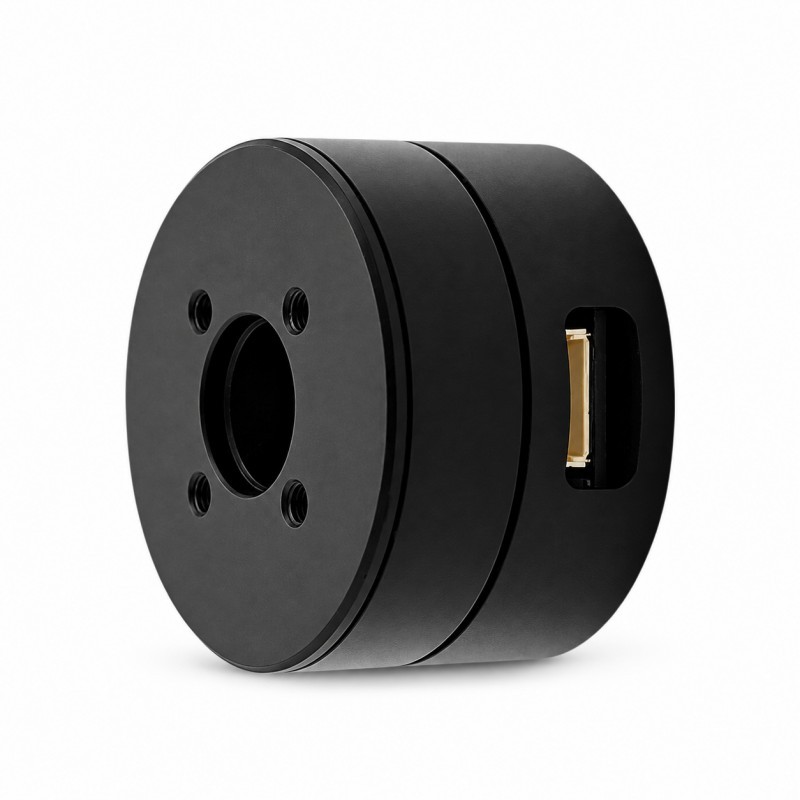
Separate Output References for Each Motion Phase
Integration into Compact 24 V Equipment
Motion Control and System Connectivity
Technical Specifications
ParameterValue
ModelT-4929
Configuration InterfaceRS485
Rated Voltage10-28 VDC
Rated Torque0.2 N·m
Peak Torque0.49N·m
Rated Power21.6W
Encoder Resolution14-Bit
CommunicationCAN
Protection RatingIP54
Weight (with driver)~134 g
Nominal speed504
Noise< 50 dB
Working Temperature-20 ~ +80 °C
Dual Encoder SupportYes (Output Shaft)
Custom Brake SupportYes
Key Applications
Humanoid Robots
Collaborative Robots
Exoskeletons
Education & Research
Medical Assistants
Smart Automation
Related Products


Review
- 加载中···
Please send your message to us
- *Name
- *Title
- *Content
POWERED BY SOLIS
Please send your message to us
- *Name
- *Title
- *Content