
POWERED BY SOLIS
 MG3505-8
 MG3505-9
 MG3505-36
 MG4315-8
 MG6010-6
 MG6010-8
 MG4305-10
 MG4310-10
 MG4310-36
 MG4310-40
 MG3510-8
 MG3510-64
 MG6010-36
 MG6010-48
 MG8108-6
 MG8108-8
 MG8108-36
 MG8108-48
 MG8115-6
 MG8115-9
 MG8115-36
 T-4024
 T-4929
 T-6034
 T-8938






Home / All / Custom Scan Motor / Hollow-Shaft Motor / MG-H109-50 Hollow Shaft Servo Motor - 50 mm Bore, 4 Nm Rated
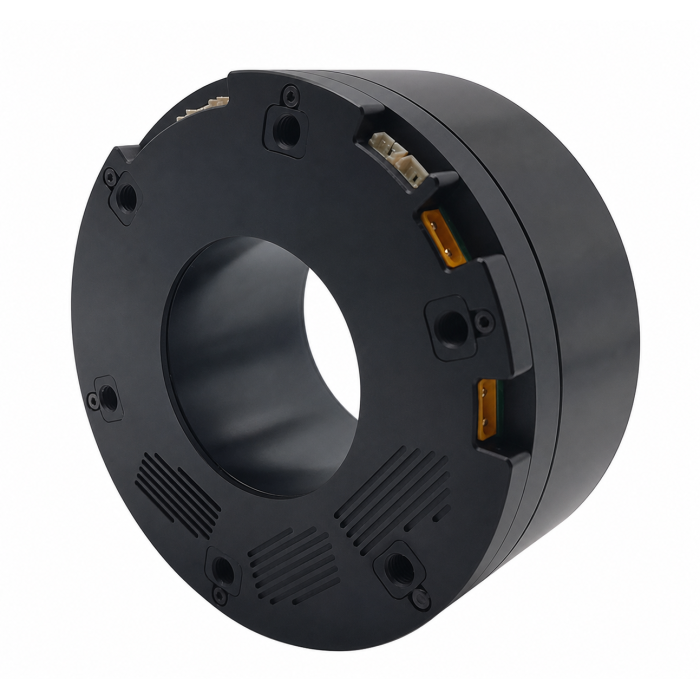
MG-H109-50 Hollow Shaft Servo Motor - 50 mm Bore, 4 Nm Rated
Detail Information
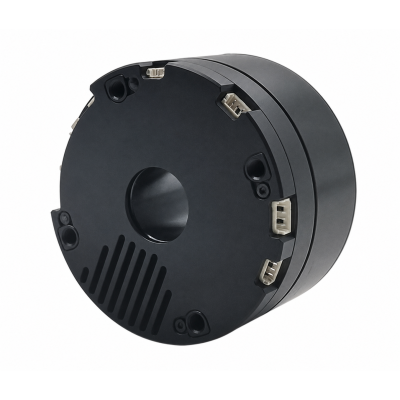
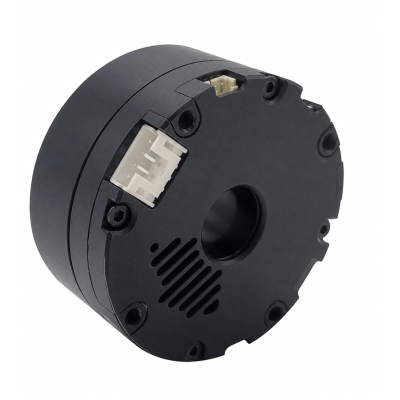
MG-H109-50 Hollow-Shaft Motor
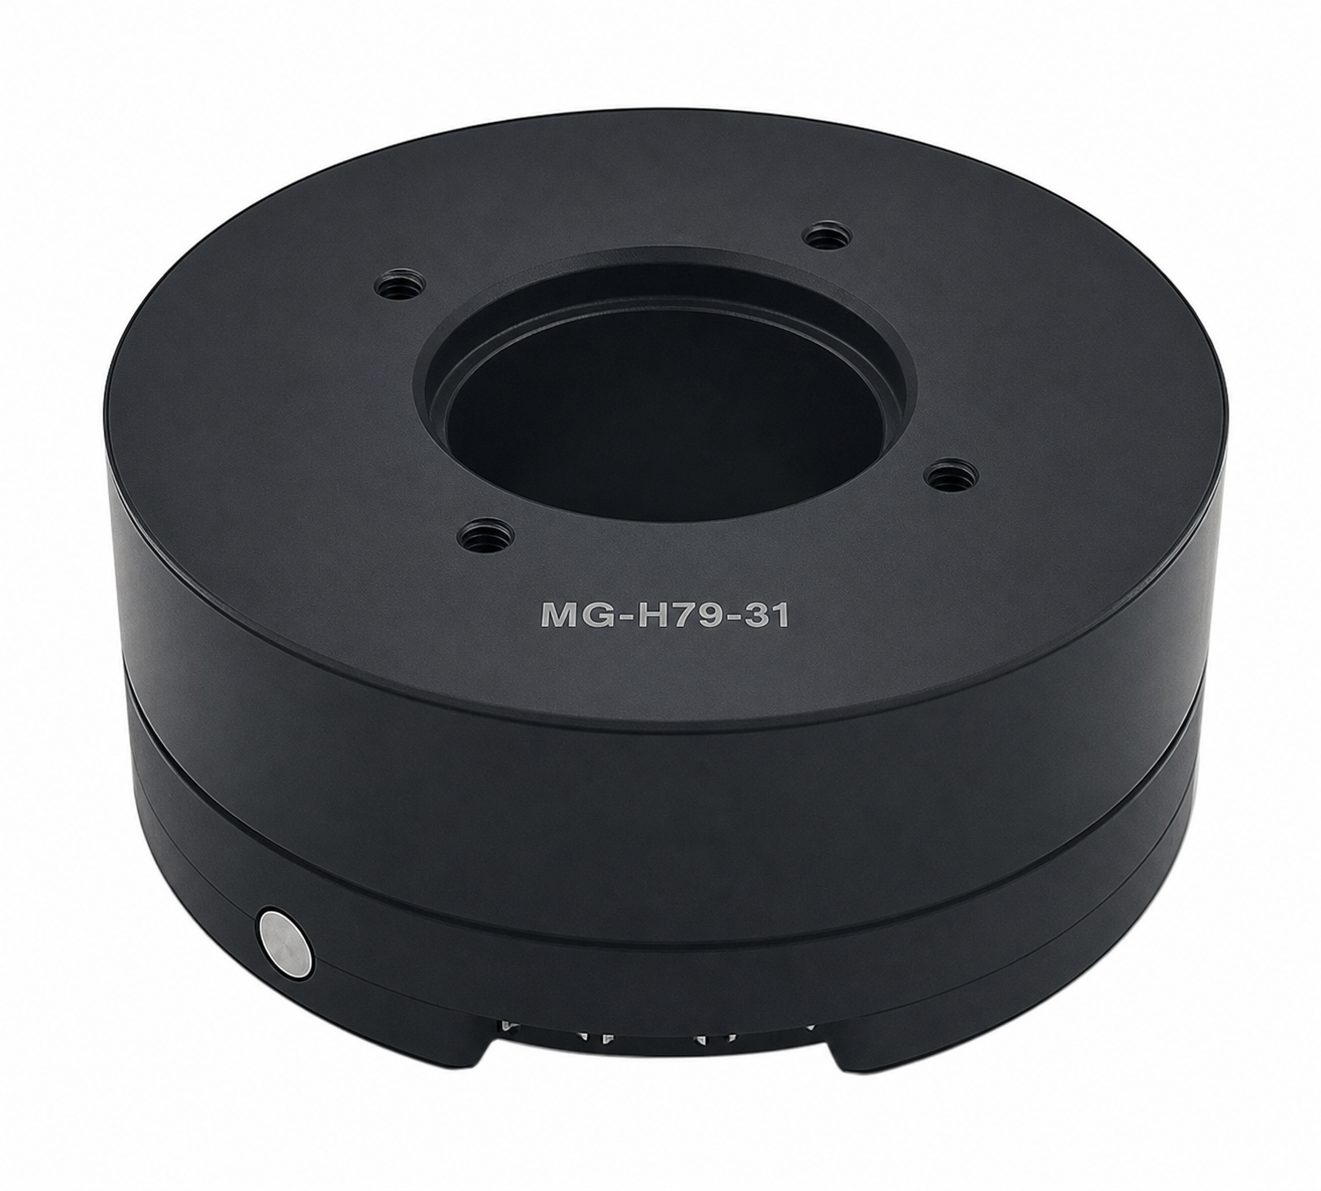
The MG-H109-50 is a high-torque hollow-shaft brushless servo motor designed for robot joints, precision rotary stages, optical equipment, and industrial automation systems.It integrates a high-torque brushless motor, servo driver, position-feedback system, and communication interfaces into a compact Ø109 × 49 mm housing. The motor features a Ø50 mm hollow bore, providing ample space for multiple power cables, communication wires, optical fibers, pneumatic lines, or mechanical components.
Operating from 24–48 VDC, the MG-H109-50 delivers 4 N·m rated torque, 15 N·m peak torque, and 384 W rated power. Its high torque density, large through-bore, and precision closed-loop control make it suitable for demanding direct-drive rotary applications.
Product Advantages
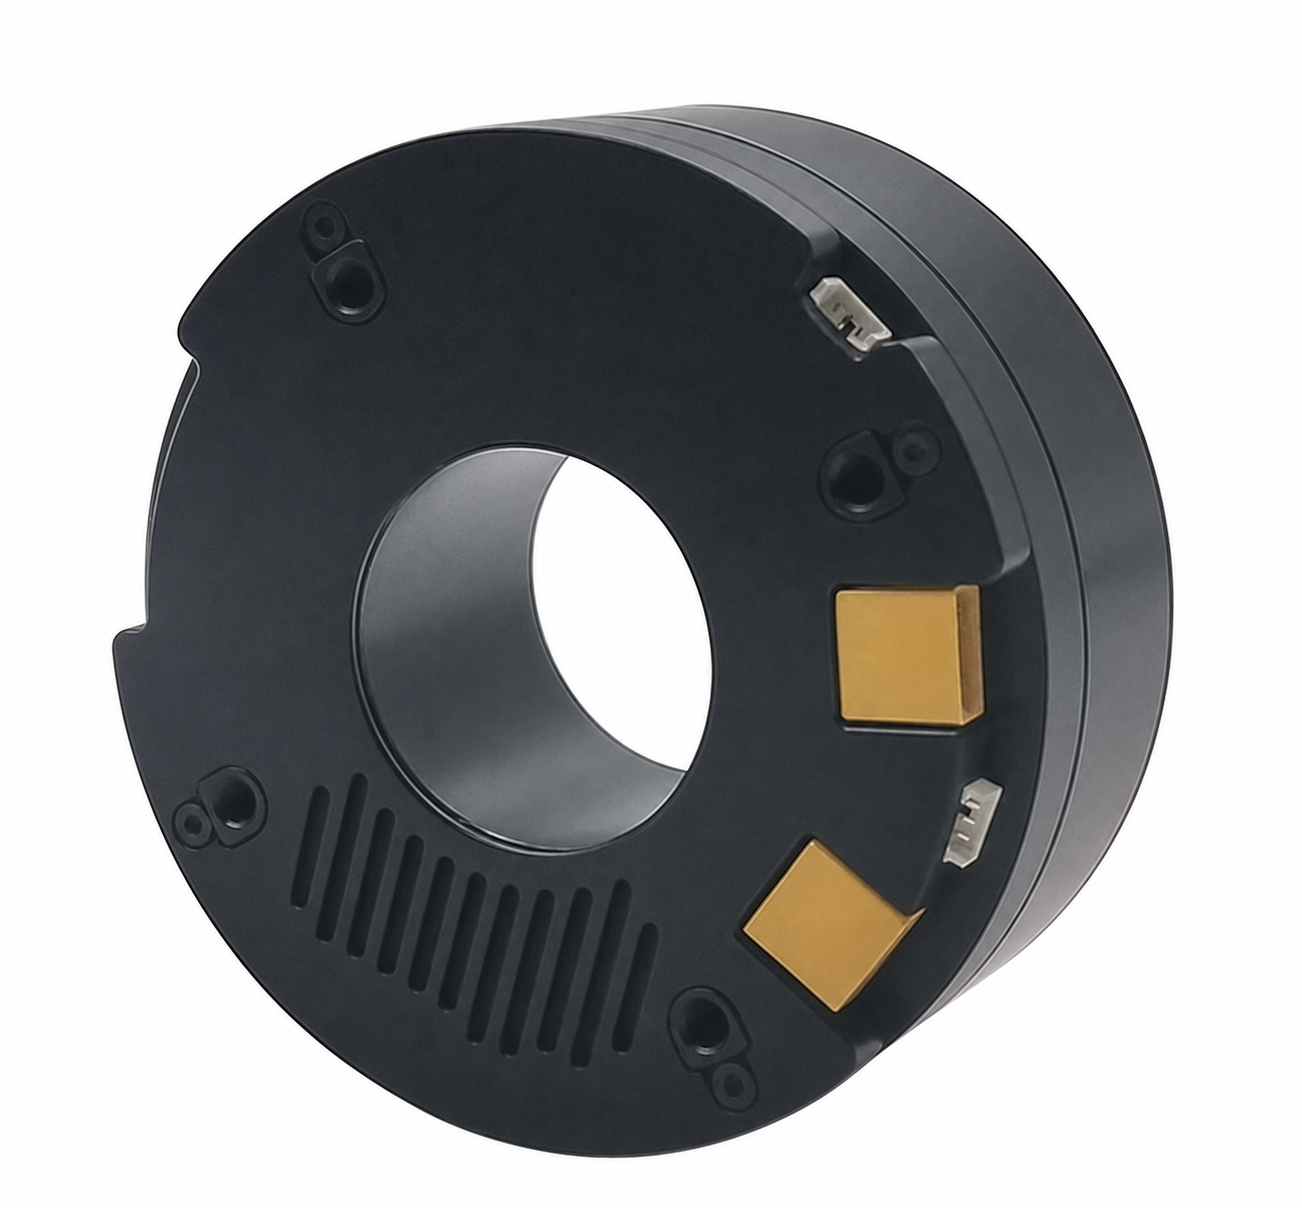
Ø50 mm Large Hollow Bore
The MG-H109-50 provides a minimum Ø50 mm hollow passage for routing multiple power cables, signal wires, optical fibers, pneumatic lines, or mechanical components through the rotation axis.The large hollow bore simplifies internal routing and reduces interference from external wiring, making it suitable for robot waist joints, optical systems, radar platforms, and complex rotary mechanisms.
4 N·m Continuous Torque
The motor delivers 4 N·m rated torque, providing reliable continuous output for robot joints, rotary stages, and automated rotary axes.Its direct-drive construction eliminates the need for an additional gearbox, avoiding mechanical backlash, transmission friction, and gear-related noise.
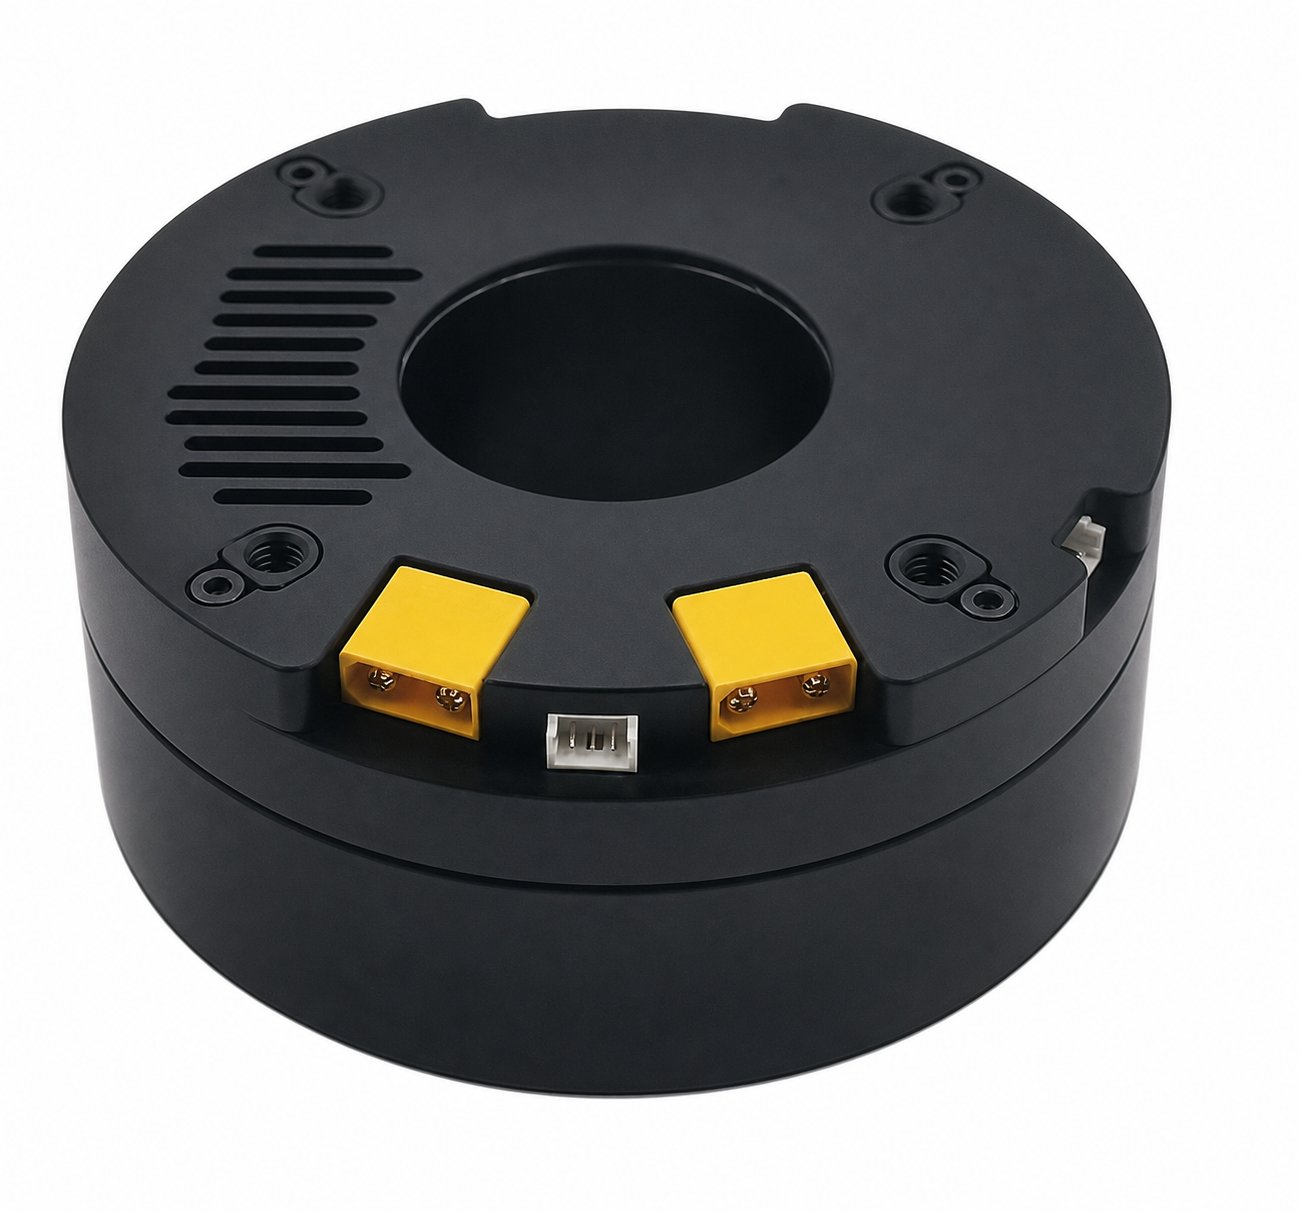
15 N·m Peak Torque
The MG-H109-50 provides up to 15 N·m peak torque, supporting startup, rapid acceleration, position holding, and short-duration impact loads.The continuous current is below 8 A, while peak current can reach 40 A. The allowable duration of peak output depends on the driver’s current limit, power-supply capacity, cooling conditions, and ambient temperature.
±0.004° Positioning Accuracy
The specified repeatability and absolute positioning accuracy are both ±0.004°, making the motor suitable for precision positioning and angle-control applications.Its speed variation rate is below ±0.5%, while the specified speed resolution is 0.0001 Hz, supporting smooth and stable low-speed operation.
20-Bit Absolute Encoder
The motor integrates a 20-bit single-turn absolute encoder, providing detailed angular feedback for position, speed, and torque control.The absolute encoder allows the controller to identify the single-turn rotor position at startup, reducing the need for conventional homing procedures.
Low-Noise, Low-Maintenance Operation
The specified operating noise is below 50 dB, making the motor suitable for laboratory equipment, optical instruments, service robots, and other noise-sensitive systems.
Technical Specifications
ParameterValue
ModelMG-H109-50
Configuration InterfaceRS485
Rated Voltage48 VDC
Rated Torque4 N·m
Peak Torque15 N·m
Rated Power384 W
Encoder Resolution20-Bit
CommunicationCAN FD
Protection RatingIP54
Weight (with driver)~1130 g
Repeatability±0.004°
Noise< 50 dB
Working Temperature-20 ~ +80 °C
Dual Encoder SupportYes (Output Shaft)
Custom Brake SupportYes
Key Applications
Humanoid Robots
Joint actuation for bipedal and full-body humanoid platforms
Collaborative Robots
Safe, precise motion for cobot arms and grippers
Exoskeletons
Power assist and rehabilitation exoskeleton systems
Education & Research
Robotics labs, university projects, and prototyping
Medical Assistants
Surgical robots and rehabilitation equipment
Smart Automation
Automated guided vehicles and smart manufacturing
Related Products
Review
- 加载中···
Please send your message to us
- *Name
- *Title
- *Content
POWERED BY SOLIS
Please send your message to us
- *Name
- *Title
- *Content