
POWERED BY SOLIS
 MG3505-8
 MG3505-9
 MG3505-36
 MG4315-8
 MG6010-6
 MG6010-8
 MG4305-10
 MG4310-10
 MG4310-36
 MG4310-40
 MG3510-8
 MG3510-64
 MG6010-36
 MG6010-48
 MG8108-6
 MG8108-8
 MG8108-36
 MG8108-48
 MG8115-6
 MG8115-9
 MG8115-36
 T-4024
 T-4929
 T-6034
 T-8938






Home / All / Robot Joint Motor / Knee Joint Motor / MGW6010-8 Exoskeleton Joint Motor - 24V, 8:1 Planetary
MGW6010-8 Exoskeleton Joint Motor - 24V, 8:1 Planetary
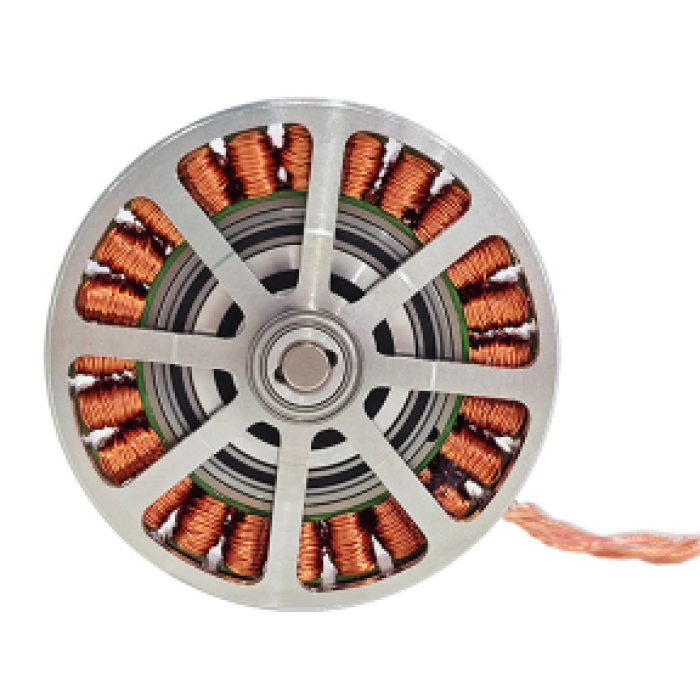
Detail Information
MGW6010-8 Integrated Robot Joint Motor
MGW6010-8 is a compact planetary geared motor designed for exoskeleton robots, rehabilitation devices, and lightweight robotic joints. It integrates a high-power-density brushless motor with an 8:1 planetary gearbox. With compact dimensions of Ø67.5 × 30.5 mm and a weight of approximately 260.5 g, it delivers 5.68 N·m of rated torque and up to 16.89 N·m of stall torque, providing a reliable drive solution for joint systems with demanding requirements for weight, installation space, and dynamic response.
Ø67.5 × 30.5 mm Ultra-Compact
5.68 N·m Rated /16.89 N·m Peak Torque
8:1 Precision Planetary Gearbox
IP54 Protection Rating
14-Bit High-Resolution Encoder
Request a Quote
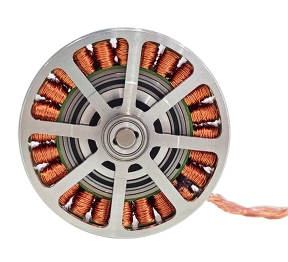
Product Advantages
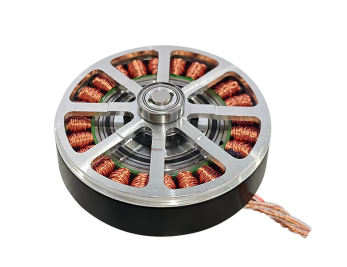
Compact Size, High Torque
Measuring only Ø67.5 × 30.5 mm, the motor delivers a rated torque of 5.68 N·m, combining strong output with a compact footprint for space-constrained joint systems.
Lightweight Joint Design
The motor weighs approximately 260.5 g. Its lightweight construction helps reduce overall exoskeleton weight and rotational inertia while improving wearer comfort and dynamic response.
8:1 Planetary Gearbox
The integrated planetary gearbox features steel gears and an 8:1 reduction ratio, increasing output torque while maintaining a high operating speed. It is well suited for robotic joints requiring continuous movement and rapid response.
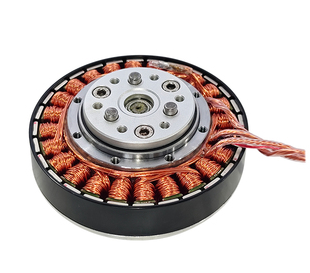
Wide Torque Output Range
With a rated torque of 5.68 N·m and a stall torque of up to 16.89 N·m, the MGW6010-8 provides the torque required for exoskeleton start-up, motion assistance, posture support, and short-duration high-load operation.
Benefit – Handles Demanding Applications
Suitable for humanoid robots, collaborative robots, and exoskeletons where high torque and compact size are essential for natural, powerful motion.
High Structural Load Capacity
With a maximum axial load of 225 N and a maximum radial load of 900 N, the motor can withstand the combined loading conditions commonly encountered in exoskeleton joints.
Adaptable to Various Operating Environments
The MGW6010-8 is rated to IP54 and operates across a temperature range of −20°C to +65°C. It provides protection against dust and splashing water, making it suitable for daily training, laboratory research, and general industrial environments.
Technical Specifications
ParameterValue
ModelMGW 6010-8
Winding MethodY (Star)
Rated Voltage24 VDC
Rated Torque5.68 N·m
Peak Torque16.89 N·m
Gear Ratio8:1 (Planetary)
Encoder Resolution14-Bit
CommunicationCAN Bus / RS485
Protection RatingIP54
Weight (with driver)~260.5 g
Dimension (with driver)Ø67.5 × 30.5 mm
Noise< 60 dB
Working Temperature-20 ~ +65 °C
Dual Encoder SupportYes (Output Shaft)
Custom Brake SupportYes
Key Applications
Humanoid Robots
Joint actuation for bipedal and full-body humanoid platforms
Collaborative Robots
Safe, precise motion for cobot arms and grippers
Exoskeletons
Power assist and rehabilitation exoskeleton systems
Education & Research
Robotics labs, university projects, and prototyping
Medical Assistants
Surgical robots and rehabilitation equipment
Smart Automation
Automated guided vehicles and smart manufacturing
Downloads
Product documents for engineering evaluation, mechanical integration and maintenance planning.
Review
- 加载中···
Please send your message to us
- *Name
- *Title
- *Content
POWERED BY SOLIS
Please send your message to us
- *Name
- *Title
- *Content